
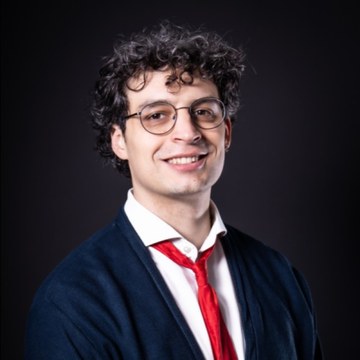
Vlad Iftime
| Title | Project Manager • Robotics Engineer • AI/ML Engineer • Full-Stack Developer |
| Education | MSc Computational Intelligence & Robotics, BSc Artificial Intelligence |
| University | University of Groningen |
| Location | Netherlands, Germany, Austria, Romania |
| vladiftime60@gmail.com |
About Me
Vlad Iftime
Project Manager • Robotics Engineer • AI/ML Engineer • Full-Stack Developer
MSc Computational Intelligence & Robotics, BSc Artificial Intelligence — University of Groningen.
A versatile engineer with 7+ years of experience spanning project leadership, robotics, artificial intelligence, and full-stack development. I thrive at the intersection of technical execution and team coordination — translating complex requirements into working systems while keeping stakeholders aligned and projects on track.
My robotics and AI work includes developing a dual-agent reinforcement learning framework for dual-arm robotic manipulation using Isaac Lab and PyTorch (MSc thesis, University of Groningen), implementing impedance control on a Franka Panda arm with ROS and C++, training NER models with Flair and TensorFlow, and building an NLP-driven patient interaction system as CTO of Aevai Health — a startup that reached the Venture Lab incubator and Philips Innovation Award finals. I've programmed embedded systems in C on STM32 microcontrollers for a solar race car and designed electronic circuits using Altium Designer.
On the full-stack side, I've built crowdfunding platforms with React, Node.js, Firebase, and Stripe integration, developed the official website for Top Dutch Solar Racing, created a social link sharing platform with SvelteKit and Tailwind CSS, and contributed to open-source energy flexibility software — implementing WebSocket communication and CI/CD pipelines with Docker and Kubernetes.
As a project manager at Seita, I grew from software developer to leading a multi-stakeholder energy flexibility initiative — coordinating a ~10-person cross-organisational team, presenting results at FOSDEM, advocating for the S2 protocol (EN 50631-1) as an emerging European standard, and driving alignment between industry partners TNO and Itho Daalderop.
I bring value as a technical leader who can architect solutions, write production code, manage stakeholders, and build high-performing teams. Based in Europe, I work remotely or on-site across the Netherlands, Germany, Austria, and Romania.
Cool Stuff
Creators, tools and inspirations I find interesting — including the ones that shaped this website.

Creator — Vleid • vista.css on GitHub
The MIT-licensed CSS framework recreating the Windows Vista Aero interface — the very framework this entire website is built on.
Creator — khang-nd • 7.css on GitHub
A Windows 7 UI framework that vista.css was built on top of — a great example of pixel-perfect nostalgia in CSS.
Creator — link here
Replace this card with a creator, tool or piece of work you find interesting — and why it's cool.
These are all my past professional experiences

Groningen, Netherlands • Dec 2024 - Dec 2025
- Grew from software developer into project lead for a multi-stakeholder energy flexibility initiative, owning the relationship between Seita, TNO, and Itho Daalderop — coordinating work packages, presenting results, and driving alignment across a ~10-person cross-organisational team; also represented the project at FOSDEM and visited large-scale industrial sites to support energy transition strategy.
- Integrated TNO's Dynamic Programming scheduling algorithm into Seita's FlexMeasures EMS platform and extended it with WebSocket support for secure, real-time communication with Itho HVAC devices; contributed to open-source repositories s2-python, flexmeasures-client, and flexmeasures-s2, and set up CI/CD pipelines (pre-commit, automated testing, Docker) to ensure code quality across the project.
- Contributed to the refinement and adoption of the S2 protocol (EN 50631-1), an emerging European standard for energy flexibility in homes and buildings, advocating for its open-source implementation as a communication standard for smart energy devices.

Groningen, Netherlands • Jul 2022 - Feb 2024
- Led the electrical and software teams in integrating complex systems and developing embedded software for the solar car project.
- Implemented agile methodologies to increase productivity and streamline project workflows, ensuring on-time delivery of key milestones.
- Developed embedded systems in C on STM microcontrollers and designed electronic circuits using Altium Designer to enhance the car functionality and reliability in harsh environments.

Groningen, Netherlands • Sep 2020 - Mar 2023
- Led the development of "Alva," an AI-driven patient interaction system using NLP, resulting in a 40% boost in engagement.
- Developed the MVP focused on personalized care, significantly improving patient management decision-making processes.
- Ensured compliance with GDPR for AI models, emphasizing data protection and privacy in healthcare.
- Contributed to Aevai Health's success in the Venture Lab incubator and Philips Innovation Award finals, showcasing the potential of AI in healthcare.

Groningen, Netherlands • Mar 2021 - Aug 2022
- Data Collection & Processing: Managed extracting and structuring large datasets from various web sources to create comprehensive, actionable databases.
- Project Collaboration: Partnered with cross-functional teams to develop innovative data solutions for future Data Explorers, enhancing data accessibility and utility for research and business applications.
- Data Quality Assurance: Ensured the integrity and quality of the data collected by applying statistical models and continuous validation processes.

Groningen, Netherlands • Feb 2021 - Mar 2021
- Developed and fine-tuned a Named Entity Recognition (NER) model, achieving an F1 score of 0.8+, using the Flair library, with Numpy and Keras for efficient data preprocessing and model training.
- Contributed to the development of a supermarket pricetag recognition system, focusing on data annotation, augmentation, and text recognition using Python and Pandas.

Brasov, Romania • Jan 2020 - Feb 2023
- Delivered custom software solutions for small to medium-sized businesses, developing CRM systems, mobile apps, and responsive websites.
- Led full-stack development across multiple projects, ensuring scalability and user-focused design, using React.js, Next.js, C#, Java, PostgreSQL, AWS, and Docker.
- Collaborated closely with clients throughout the project lifecycle to deliver high-quality, efficient software solutions.

Groningen, Netherlands • During my Bachelors and Masters
- Teaching Assistant for Human-Robot Interaction & Social Robots: Provided detailed evaluations and constructive feedback on students' projects and offered personalized guidance through office hours, tutorials, and online forums.
- Teaching Assistant for Robotics Practical: Helped students understand the basics of ROS and robotic systems; supervised the University Robotics lab.
- Teaching Assistant for Cognitive Robotics : Helped students understand cognitive robotic systems; reviewed papers, essays, and projects on 3D object perception, affordance detection, and manipulation.
- Teaching Assistant for Linear Algebra & Multivariable Calculus: Prepared and taught tutorials, graded assignments and exams, and created online learning materials during COVID.
- Teaching Assistant for Object-Oriented Programming: Taught OOP basics in Java, graded assignments, and supported student teams.
- Teaching Assistant for Neurophysics: Taught introductory mechanical and electrical physics applied to understanding the brain.
- Teaching Assistant for Imperative Programming: Taught the basics of programming in C.
Mostly my technical skills
Projects I've worked on trough the years and that I kinda like, they're kinda cool
 Isaac Sim
 PyTorch
• Jan 2025 - May 2026 (MSc Thesis)
 github.com/VladIftime/master_isaac
- Developed a dual-agent adversarial self-play reinforcement learning framework (PPO + Behavioral Cloning) in Isaac Sim, training two adversarial policies—a goal-proposer and a goal-solver—to autonomously generate and master a curriculum of dual-arm manipulation tasks on UR5e robots without manual reward engineering.
- Integrated cuRobo's GPU-accelerated batch IK solver into the RL training loop, building a custom kinematic pipeline that decodes discretized policy actions into 6-DoF end-effector delta targets across up to 4096 parallel environments.
- Designed a permutation-invariant GoalEncoder network that compresses multi-object goal states into learned 8D latent embeddings, enabling the solver agent to condition on abstract goal representation.
- Implemented a single-agent Push-PPO baseline with a 4D macro-action space and multi-phase push primitive trajectory generator, enabling direct comparison between learned adversarial curricula and conventional dense-reward RL.
Isaac Lab / Isaac Sim
PyTorch
 Python (stable-baselines3)
• 2025 - 2026
- Built a single-arm object-throwing reinforcement learning environment in Isaac Lab, where a dual-arm UR5e robot (Robotiq 2F-140 grippers) learns to throw a drink bottle into a shopping basket placed at randomized positions on a nearby table.
- Implemented two control regimes: per-step 6-DoF end-effector deltas (PPO) executed through swappable IK solvers (DiffIK, OSC, RMPflow, cuRobo), and a SAC macro-action pipeline where one RL step is an entire throw defined by a 4-parameter Gazebo-style catapult primitive.
- Engineered kinematic object attachment with velocity-triggered release inside a DirectRLEnv state machine running 320 physics sub-steps per RL step, training 2048 parallel environments with auto-resume on HPC (Apptainer + SLURM).
- Built a validation pipeline evaluating checkpoints against 10 randomized targets with per-target pass/fail reports, heatmaps, and reproducible results via PhysX enhanced determinism.
Isaac Lab / Isaac Sim
PyTorch
Python (skrl)
• 2025 - 2026
- Built a competitive table-tennis simulation in Isaac Lab, pitting two dual-arm UR5e robots against each other across a regulation-size table in full rallies.
- Implemented a virtual paddle-contact model — the racket surface is computed from the playing arm's wrist link pose with a 6 cm distance threshold, requiring no contact sensors.
- Ported the full game logic from Isaaclab-TableTennisRobot: table-zone scoring, alternating randomized ball serves, and Gazebo-style reward shaping (contact, velocity, table zones).
- Exposed four interchangeable IK solvers (DiffIK, OSC, RMPflow, cuRobo) through a single interface, plus a swing macro-primitive that decodes 5 parameters into a full multi-phase stroke (backswing, contact, follow-through) with SLERP-interpolated waypoints.


- Built an open-source CSS framework that recreates the Windows Vista Aero design from semantic HTML — no JavaScript required.
- Extended 7.css (descended from XP.css and 98.CSS) with Vista title bars, taskbar & start orb, glass windows, gadgets, and a CSS-only bubbles screensaver.
- Ships a scoped build variant and is compatible with any frontend framework; MIT licensed.
- Powers this portfolio — vladifti.me is entirely styled with vista.css.
 WebGL
 JavaScript
 CI/CD (GitHub Actions)
• Aug 2026
- Built a zero-dependency WebGL 1.0 soap-bubble screensaver in a single ~14 KB file.
- Implements physically based thin-film light interference — spectral reflectivities precomputed into a 256×256 lookup texture (Iwasaki, Matsuzawa & Nishita, CGI 2004) and applied per frame with a two-pass GPU blend.
- Idle-aware screensaver mode: bubbles appear after a configurable idle delay and vanish instantly on any activity; dispatches bubbles-show / bubbles-hide events for UI coordination.
- MIT licensed; runs as the idle screensaver of this portfolio.
 SvelteKit
 Tailwind CSS
 Firebase
• Dec 2023 - Jan 2024
- Developed a full-stack web application inspired by Linktree.
- Tech Stack: SvelteKit and Tailwind CSS for frontend, Firebase for backend services including authentication and database management.
- Implemented features like user authentication, complex forms, Tailwind CSS for styling, and real-time data manipulation.
 React
 Node.js
Firebase
 Stripe
 MailChimp
• Jan 2023 - Aug 2023
- Built a full-stack crowdfunding platform from scratch, handling secure payments via Stripe and real-time campaign tracking with Firebase.
- Integrated MailChimp for automated backer updates, boosting engagement and transparency throughout the campaign.
- Led the end-to-end development process, taking the project from concept to fully deployed product, raising over 1.5k euros in donations.

React
 Bootstrap
• Oct 2022 - Sep 2023
- Developed the official website for Top Dutch Solar Racing to showcase the team, attract sponsors, highlight achievements, and provide race updates.
- Built a blog for updates and news, a sponsor showcase page, custom animations, and responsive design for accessibility across devices.
- Technologies: React for dynamic and responsive UI, Bootstrap for mobile-first design.
Leadership, Safety • Jan 2023 - Nov 2023
- Served as the Safety Officer for Top Dutch Solar Racing during the Bridgestone World Solar Challenge, ensuring team safety and compliance with event regulations.
- Authored safety protocols aligning with event rules, managed emergency supplies inventory, and conducted training on emergency response protocols.
- Led roadside repair situations with a focus on safety, ensuring quick and safe resolutions to technical issues.
- Recognized with the Team Safety Award by the Bridgestone World Solar Challenge for outstanding safety standards, marking the team as the safest during the event.
 C++
 ROS
• Jul 2022
- Represented the University of Groningen as a co-team lead at the European Robotics Forum 2022 Hackathon, tackling the Franka challenge.
- Designed a robotic system capable of dealing with electronic waste over a 2-week period, proving the feasibility of using robotic manipulators for complex tasks such as disassembly.
- Wrote a scientific report on Automatic E-waste Recycling Using Robotic Manipulators.
C++
ROS
• Apr 2019 - Jun 2019
- Used the principles of impedance control to perform a blind search in which a Franka Panda robotic arm had to find, pick up, then stack objects from a table.
- The robotic arm used force sensors to determine the shape of objects and then determined how to grasp them.
- All programming was done in C++ with strong knowledge of ROS and the Linux Kernel.
CV / Resume
My CV is available as a PDF. Open it in your browser or download it:
Contact
| vladiftime60@gmail.com | |
| Phone | +31 6 3007 1369 |
| linkedin.com/in/vlad-iftime | |
| GitHub | github.com/VladIftime |
Credits & Attribution
Windows Vista, Windows Aero, and the associated icons, imagery, and sounds are © Microsoft Corporation. All rights reserved.
- Desktop wallpaper — Windows Vista default wallpaper, distributed with vista.css.
-
Welcome Center graphics — aurora header,
glass title band, and command-link glyphs extracted from
oobefldr.dll(Windows Vista Ultimate SP2 x64, sourced from archive.org). -
Icons — Windows Vista system icons extracted
from
imageres.dll. -
Startup sound — Windows Vista startup sound
(
imageres.dll, WAVE resource 5051). - Taskbar & UI imagery — extracted from Windows Vista system libraries, distributed with vista.css. See the vista.css NOTICE.md for full attribution.
These assets are used for non-commercial, personal, and educational purposes. No affiliation with or endorsement by Microsoft is implied.
The bubble overlay is a real-time WebGL replica of the Windows Vista Bubbles screensaver, implementing the thin-film interference method described in "Real-time Rendering of Soap Bubbles Taking into Account Light Interference" by Iwasaki, Matsuzawa & Nishita (CGI 2004, University of Tokyo).